robotswerve
Container to hold the main robot code.
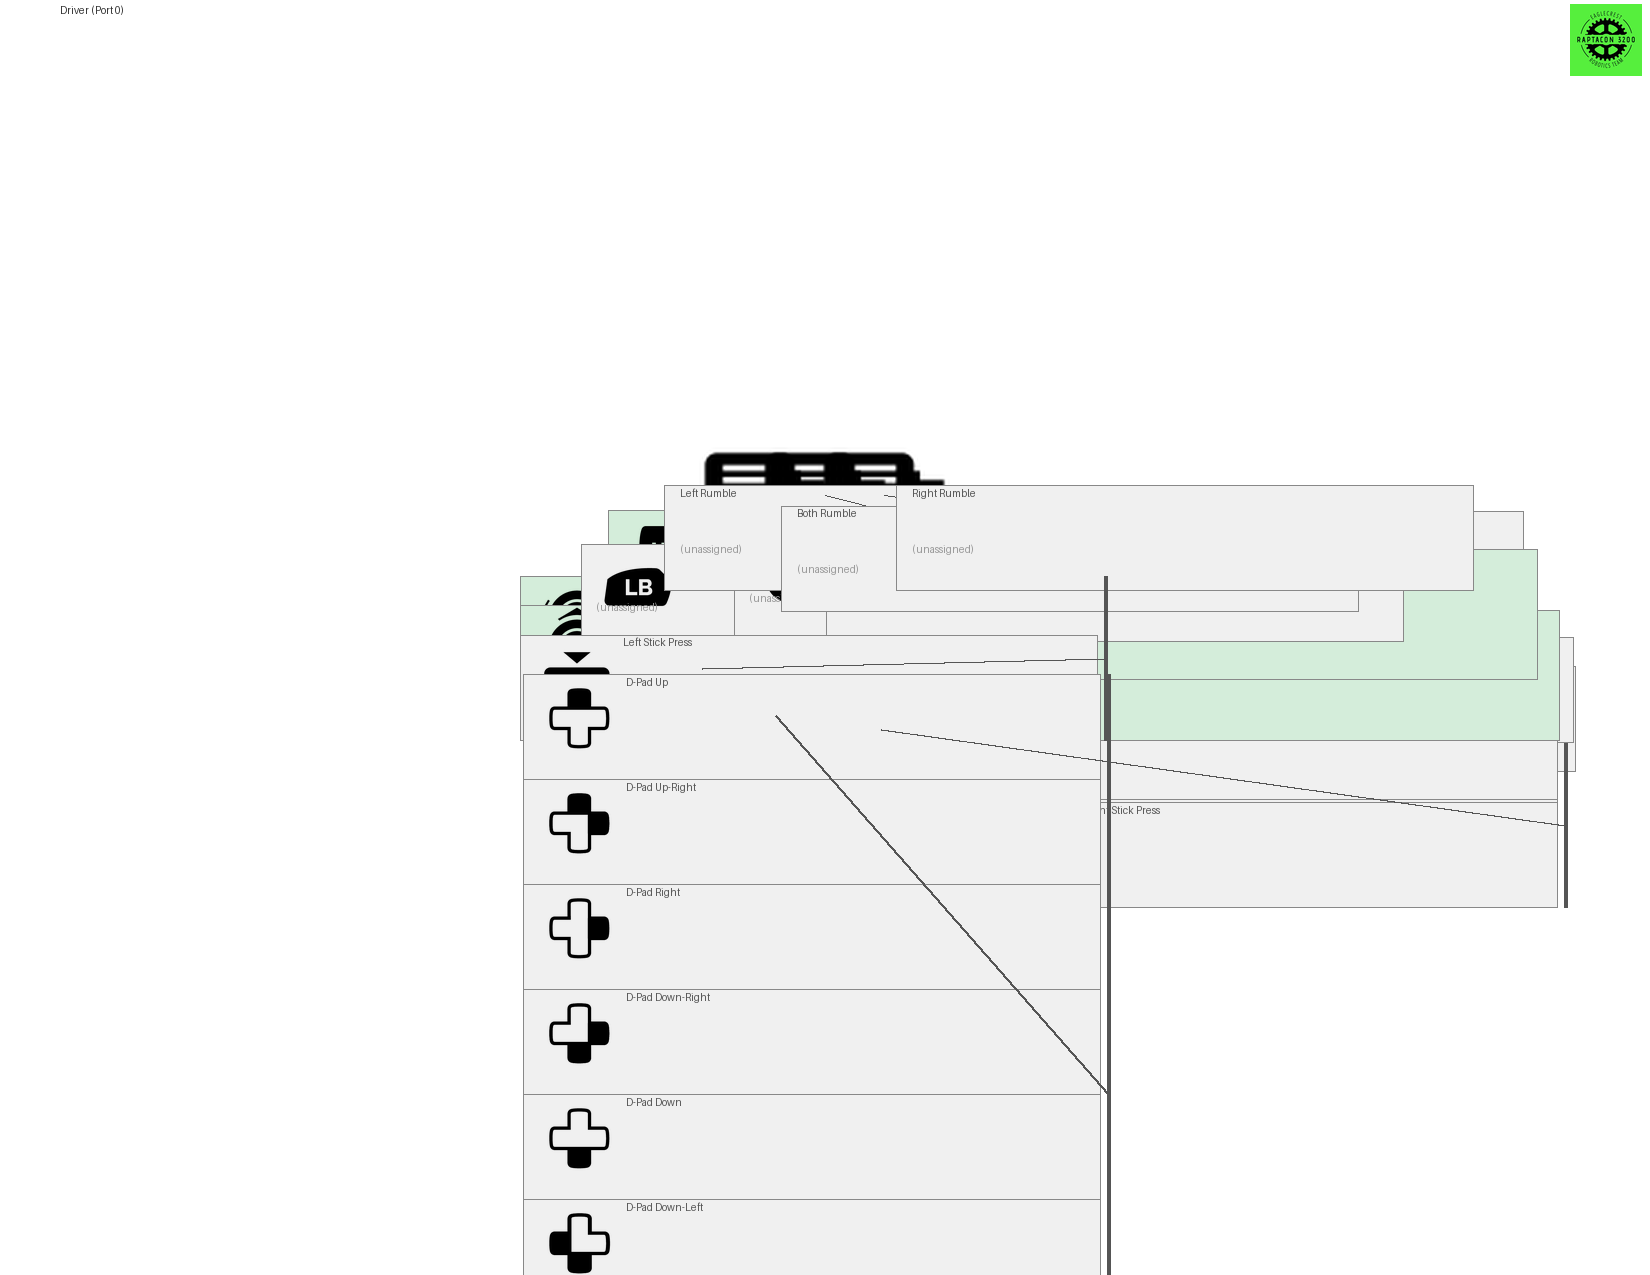
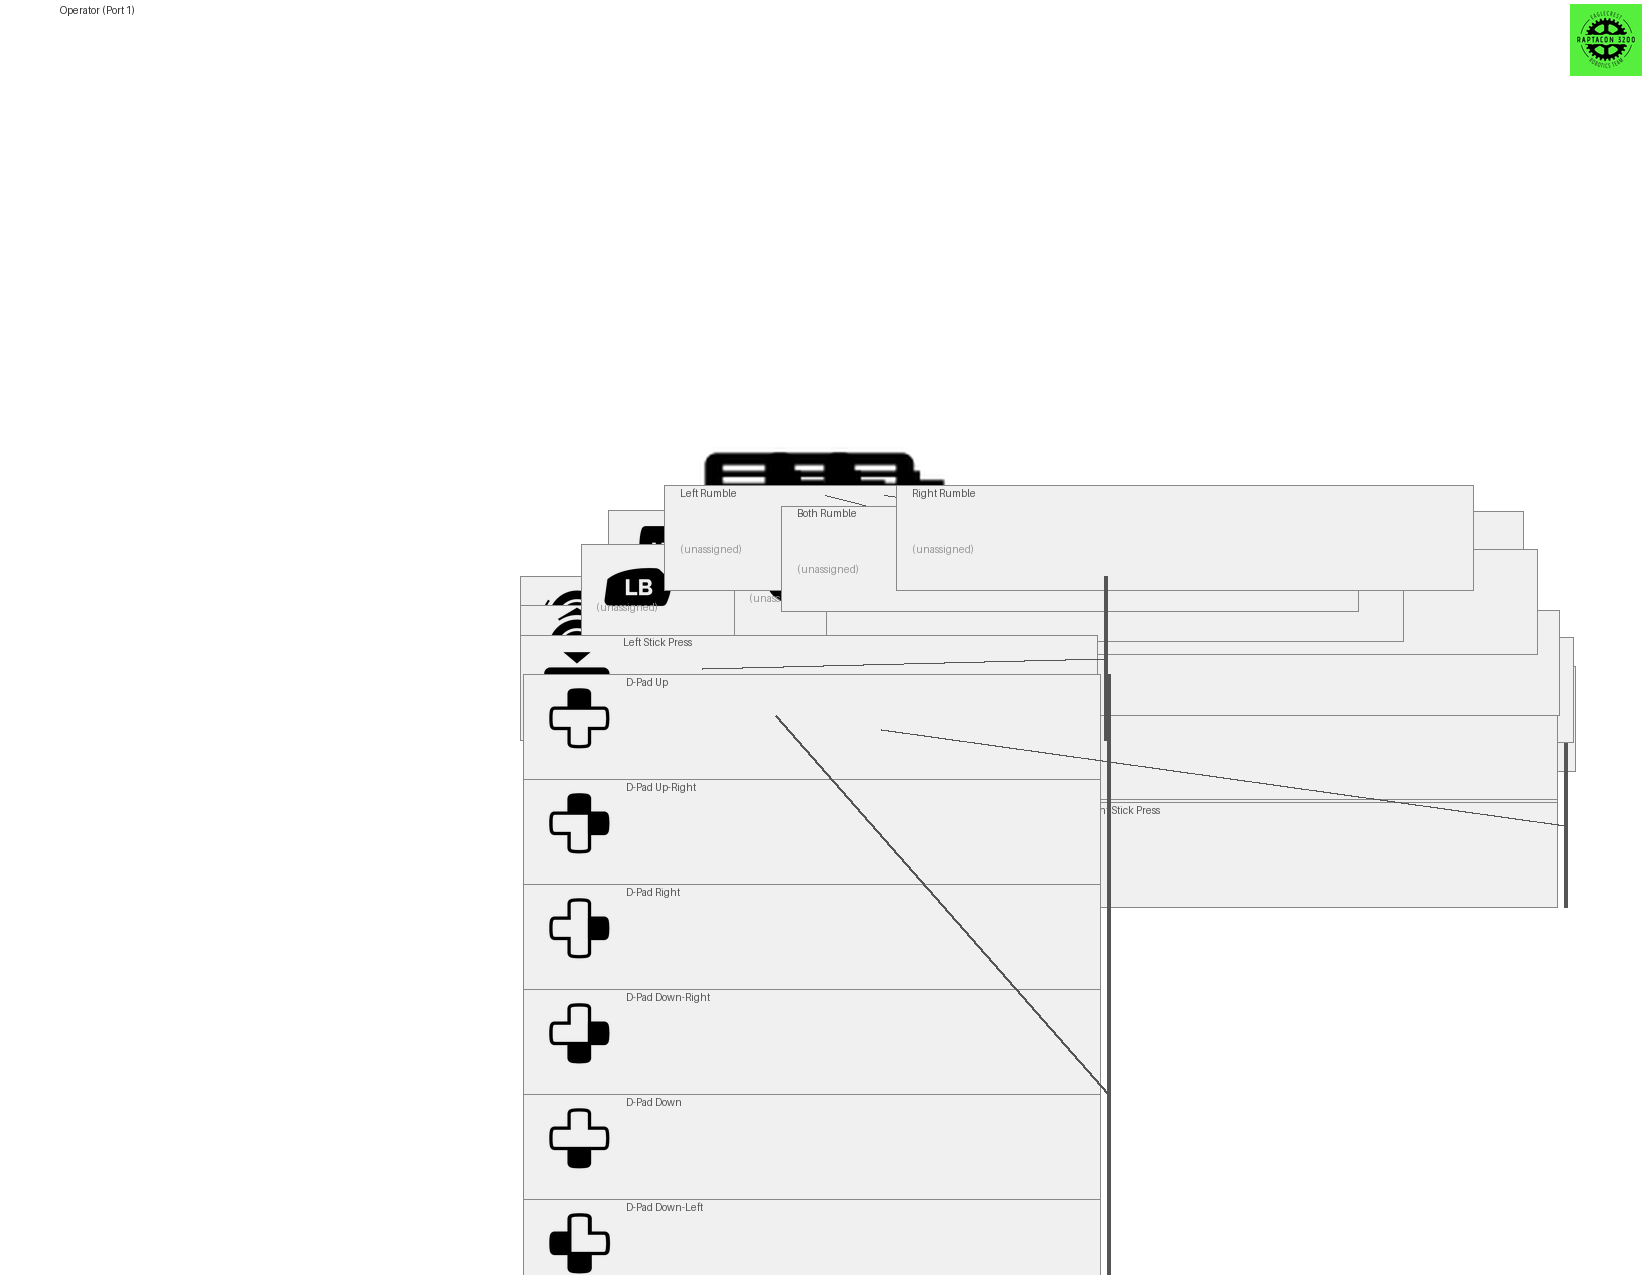
Controller Map
1""" 2Container to hold the main robot code. 3 4## Controller Map 5 6 7 8 9""" 10 11# Native imports 12import json 13import os 14from pathlib import Path 15from typing import Callable 16 17# Internal imports 18from config import HoodConfig, OperatorRobotConfig 19import constants.swerve_constants as consts 20from data.telemetry import Telemetry 21import commands 22import subsystem 23from subsystem.health_and_status import HealthAndStatus 24from subsystem.nfc_battery_tracker import NfcBatteryTracker 25from subsystem.robot_state import RobotState 26from utils.input import InputFactory 27from utils.odometry_logic_2026 import determineShooterTargets2026 28 29# Third-party imports 30import commands2 31import wpilib 32from pathplannerlib.auto import AutoBuilder 33from wpimath.geometry import Rotation2d 34 35class RobotSwerve: 36 def __init__(self, is_disabled: Callable[[], bool]) -> None: 37 # networktables setup 38 self.field = wpilib.Field2d() 39 wpilib.SmartDashboard.putData("Field", self.field) 40 41 # In simulation, pre-seed CANcoder supply voltage so the absolute 42 # encoders report valid data when swerve modules call 43 # baseline_relative_encoders() during construction. 44 if wpilib.RobotBase.isSimulation(): 45 import phoenix6 46 for base_id in OperatorRobotConfig.swerve_module_channels: 47 encoder_id = base_id + 2 48 encoder = phoenix6.hardware.CANcoder(encoder_id) 49 encoder.sim_state.set_supply_voltage(12.0) 50 51 # Subsystem instantiation 52 self.drivetrain = subsystem.drivetrain.swerve_drivetrain.SwerveDrivetrain() 53 self.health_and_status = HealthAndStatus() 54 self.nfc_battery_tracker = NfcBatteryTracker() 55 from subsystem.localization.localization import Localization 56 self.localization = Localization(self.drivetrain, field=self.field) 57 self._vision_cycle_counter = 0 58 59 # Mechanism subsystems — toggle each to True/False individually 60 _enable_shooter = False 61 _enable_feed = False 62 _enable_hood = False 63 _enable_hopper = False 64 _enable_intake_position = False 65 _enable_intake_roller = True 66 67 self.shooter = subsystem.mechanisms.shooter.Shooter() if _enable_shooter else None 68 self.feed = subsystem.mechanisms.shooter.Feed() if _enable_feed else None 69 self.hood = subsystem.mechanisms.shooter.createHood(consts.HoodConstants, HoodConfig) if _enable_hood else None 70 self.hopper = subsystem.Hopper() if _enable_hopper else None 71 self.intake_position = subsystem.IntakePosition() if _enable_intake_position else None 72 self.intake_roller = subsystem.IntakeRoller() if _enable_intake_roller else None 73 self.robot_state = RobotState() 74 # Alliance instantiation 75 self.updateAlliance() 76 77 # Initialize timer 78 self.timer = wpilib.Timer() 79 self.timer.start() 80 81 # HID setup — config-driven via InputFactory 82 wpilib.DriverStation.silenceJoystickConnectionWarning(True) 83 self.factory = InputFactory(config_path="data/inputs/2026bot.yaml") 84 85 # Speed toggle state 86 self._drive_scale_slow = 0.25 87 self._drive_scale_fast = 1 88 self._drive_is_slow = False 89 90 # TODO: Move input retrieval and binding into commands/{subsystem}_controls.py 91 # files as part of the subsystem registry refactor. Each subsystem's controls 92 # module should own its own factory.get*() calls and command wiring. 93 self._configure_controls() 94 95 # Autonomous setup 96 self.auto_command = None 97 self.auto_chooser = AutoBuilder.buildAutoChooser() 98 wpilib.SmartDashboard.putData("Select auto routine", self.auto_chooser) 99 100 # Telemetry setup 101 wpilib.SmartDashboard.putNumber("Drivetrain speed", self._drive_scale_fast) 102 self._enable_telemetry = wpilib.SmartDashboard.getBoolean("enableTelemetry", True) 103 if self._enable_telemetry: 104 self.telemetry = Telemetry( 105 driveTrain=self.drivetrain, 106 ) 107 108 wpilib.SmartDashboard.putString("Robot Version", self.getDeployInfo("git-hash")) 109 wpilib.SmartDashboard.putString("Git Branch", self.getDeployInfo("git-branch")) 110 111 112 113 def robotPeriodic(self): 114 self._vision_cycle_counter += 1 115 if self._vision_cycle_counter >= OperatorRobotConfig.vision_update_rate_divisor: 116 self._vision_cycle_counter = 0 117 self.localization.update() 118 119 if self._enable_telemetry and self.telemetry: 120 self.telemetry.runDefaultDataCollections() 121 122 self.field.setRobotPose(self.drivetrain.current_pose()) 123 124 def disabledInit(self): 125 self.updateAlliance() 126 self.drivetrain.set_motor_stop_modes(to_drive=True, to_break=True, all_motor_override=True, burn_flash=False) 127 self.drivetrain.stop_driving() 128 self.nfc_battery_tracker.onDisabledInit() 129 130 if self.shooter: 131 self.shooter.setRPM(0) 132 self.shooter.resetOffset() 133 if self.feed: 134 self.feed.stop() 135 if self.hopper: 136 self.hopper.stop() 137 if self.intake_roller: 138 self.intake_roller.stop() 139 if self.intake_position: 140 self.intake_position.disable() 141 142 def disabledPeriodic(self): 143 pass 144 145 146 def autonomousInit(self): 147 self.updateAlliance() 148 self.auto_command = self.auto_chooser.getSelected() 149 if self.auto_command: 150 self.auto_command.schedule() 151 if self.auto_command.getName().lower() == "instantcommand": 152 self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose()) 153 else: 154 self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose()) 155 156 def autonomousPeriodic(self): 157 pass 158 159 def teleopInit(self): 160 self.updateAlliance() 161 if self.auto_command: 162 self.auto_command.cancel() 163 if self.auto_command.getName().lower() == "instantcommand": 164 self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose()) 165 else: 166 self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose()) 167 168 # DefaultDrive: raw square input (diagonals get full per-axis output) 169 # DefaultDriveCircular: remaps circular stick input so diagonals 170 # reach full speed (use when stick hardware caps diagonal ~70%) 171 self.drivetrain.setDefaultCommand( 172 commands.default_swerve_drive.DefaultDrive( # TODO: switch back to DefaultDriveCircular 173 self.drivetrain, 174 self.translate_x, 175 self.translate_y, 176 self.rotate, 177 lambda: not self.robot_relative_btn() 178 ) 179 ) 180 181 if self.hood: 182 self.hood.setDefaultCommand(self.hood.autoAngleCommand()) 183 184 def teleopPeriodic(self): 185 pass 186 187 def testInit(self): 188 self.updateAlliance() 189 commands2.CommandScheduler.getInstance().cancelAll() 190 # See teleopInit for DefaultDrive vs DefaultDriveCircular notes 191 self.drivetrain.setDefaultCommand( 192 commands.default_swerve_drive.DefaultDrive( # TODO: switch back to DefaultDriveCircular 193 self.drivetrain, 194 self.translate_x, 195 self.translate_y, 196 self.rotate, 197 lambda: not self.robot_relative_btn() 198 ) 199 ) 200 commands2.cmd.run(lambda: self.drivetrain.drive(2, 0, 0, False), self.drivetrain).withTimeout(5).schedule() 201 202 if self.hood: 203 self.hood.setDefaultCommand( 204 self.hood.manualTestCommand(self.hood_angle_input)) 205 206 def testPeriodic(self): 207 pass 208 209 def _configure_controls(self) -> None: 210 """Retrieve managed inputs from the factory and wire command bindings. 211 212 TODO: Move into commands/{subsystem}_controls.py files as part of the 213 subsystem registry refactor. Each subsystem's controls module would 214 call register_controls(subsystem, container) and own its own 215 factory.get*() calls and command wiring. 216 """ 217 # Managed drive inputs 218 self.translate_x = self.factory.getAnalog("drivetrain.translate_x") 219 self.translate_y = self.factory.getAnalog("drivetrain.translate_y") 220 self.rotate = self.factory.getAnalog("drivetrain.rotate") 221 self.robot_relative_btn = self.factory.getRawButton("drivetrain.robot_relative") 222 223 # Cancel-all: emergency stop all commands 224 self.factory.getButton("drivetrain.cancel_all").bind( 225 commands2.cmd.runOnce( 226 lambda: commands2.CommandScheduler.getInstance().cancelAll() 227 ) 228 ) 229 230 # Speed toggle: switch between slow and fast drive scale 231 self.factory.getButton("drivetrain.speed_toggle").bind( 232 commands2.cmd.runOnce(self._toggle_drive_scale) 233 ) 234 235 # Auto-rotate: align drivetrain to target while held 236 self.factory.getButton("drivetrain.auto_align").bind( 237 commands.auto.pid_to_angle.PIDAlignToTarget( 238 self.drivetrain, 239 lambda: determineShooterTargets2026(self.drivetrain.current_pose, self.alliance), 240 self.translate_x, 241 self.translate_y, 242 lambda: not self.robot_relative_btn(), 243 alignment_angle=Rotation2d.fromDegrees(180) 244 ) 245 ) 246 247 # Mechanism controls — only registered when subsystems are enabled 248 if self.shooter: 249 self.factory.getButton("shooter.increment_RPM").bind( 250 commands2.cmd.runOnce(lambda: self.shooter.modifyOffset(consts.ShooterConstants.offsetDelta), self.shooter) 251 ) 252 self.factory.getButton("shooter.decrement_RPM").bind( 253 commands2.cmd.runOnce(lambda: self.shooter.modifyOffset(-consts.ShooterConstants.offsetDelta), self.shooter) 254 ) 255 self.factory.getButton("shooter.reset_RPM_offset").bind( 256 commands2.cmd.runOnce(self.shooter.resetOffset, self.shooter) 257 ) 258 259 if self.hood: 260 self.hood_angle_input = self.factory.getAnalog("hood.angle") 261 262 if self.hopper: 263 self.factory.getButton("hopper.toggle_hopper").bind( 264 commands.ball_transport.run_hopper_while_active(self.hopper) 265 ) 266 267 if self.intake_position: 268 self.factory.getButton("intake.toggle_deploy").bind( 269 commands.intake_commands.toggle_intake_deploy(self.intake_position) 270 ) 271 272 if self.intake_roller: 273 self.factory.getButton("ball_transport.hold_roller").bind( 274 commands.ball_transport.run_roller_while_held(self.intake_roller) 275 ) 276 277 if self.shooter and self.hood: 278 self.factory.getButton("shooter.spinup_toggle").bind( 279 commands.shooter_commands.toggle_spinup(self.shooter, self.hood) 280 ) 281 282 if self.hopper and self.feed: 283 self.factory.getButton("ball_transport.run_hopper_feed").bind( 284 commands.ball_transport.run_hopper_and_feed(self.hopper, self.feed) 285 ) 286 287 #Turret stop 288 # Map all drive axes' scale to a shared SmartDashboard entry. 289 # Dashboard changes and Y-button toggles both write to this path; 290 # the factory auto-syncs the value into all three analogs each cycle. 291 _SPEED_NT = "/SmartDashboard/Drivetrain speed" 292 for analog in (self.translate_x, self.translate_y, self.rotate): 293 analog.mapParamToNtPath(_SPEED_NT, "scale") 294 295 def _toggle_drive_scale(self) -> None: 296 """Toggle between slow and fast drive scale presets. 297 298 Writes the new scale to SmartDashboard; the factory auto-syncs 299 it into all three drive analogs via mapParamToNtPath each cycle. 300 """ 301 self._drive_is_slow = not self._drive_is_slow 302 scale = self._drive_scale_slow if self._drive_is_slow else self._drive_scale_fast 303 wpilib.SmartDashboard.putNumber("Drivetrain speed", scale) 304 305 def getDeployInfo(self, key: str) -> str: 306 """Gets the Git SHA of the deployed robot by parsing ~/deploy.json and returning the git-hash from the JSON key OR if deploy.json is unavailable will return "unknown" 307 example deploy.json: '{"deploy-host": "DESKTOP-80HA89O", "deploy-user": "ehsra", "deploy-date": "2023-03-02T17:54:14", "code-path": "blah", "git-hash": "3f4e89f138d9d78093bd4869e0cac9b61becd2b9", "git-desc": "3f4e89f-dirty", "git-branch": "fix-recal-nbeasley"} 308 309 Args: 310 key (str): The desired json key to get. Popular onces are git-hash, deploy-host, deploy-user 311 312 Returns: 313 str: Returns the value of the desired deploy key 314 """ 315 json_object = None 316 home = str(Path.home()) + os.path.sep 317 release_file = home + 'py' + os.path.sep + "deploy.json" 318 try: 319 # Read from ~/deploy.json 320 with open(release_file, "r") as openfile: 321 json_object = json.load(openfile) 322 if key in json_object: 323 return json_object[key] 324 else: 325 return f"Key: {key} Not Found in JSON" 326 except OSError: 327 return "unknown" 328 except json.JSONDecodeError: 329 return "bad json in deploy file check for unescaped " 330 331 def updateAlliance(self) -> None: 332 """ 333 Update the alliance the robot is on 334 """ 335 self.alliance = wpilib.DriverStation.getAlliance() 336 self.drivetrain.update_alliance_flag(self.alliance)
class
RobotSwerve:
 36class RobotSwerve:
 37    def __init__(self, is_disabled: Callable[[], bool]) -> None:
 38        # networktables setup
 39        self.field = wpilib.Field2d()
 40        wpilib.SmartDashboard.putData("Field", self.field)
 41
 42        # In simulation, pre-seed CANcoder supply voltage so the absolute
 43        # encoders report valid data when swerve modules call
 44        # baseline_relative_encoders() during construction.
 45        if wpilib.RobotBase.isSimulation():
 46            import phoenix6
 47            for base_id in OperatorRobotConfig.swerve_module_channels:
 48                encoder_id = base_id + 2
 49                encoder = phoenix6.hardware.CANcoder(encoder_id)
 50                encoder.sim_state.set_supply_voltage(12.0)
 51
 52        # Subsystem instantiation
 53        self.drivetrain = subsystem.drivetrain.swerve_drivetrain.SwerveDrivetrain()
 54        self.health_and_status = HealthAndStatus()
 55        self.nfc_battery_tracker = NfcBatteryTracker()
 56        from subsystem.localization.localization import Localization
 57        self.localization = Localization(self.drivetrain, field=self.field)
 58        self._vision_cycle_counter = 0
 59
 60        # Mechanism subsystems — toggle each to True/False individually
 61        _enable_shooter = False
 62        _enable_feed = False
 63        _enable_hood = False
 64        _enable_hopper = False
 65        _enable_intake_position = False
 66        _enable_intake_roller = True
 67
 68        self.shooter = subsystem.mechanisms.shooter.Shooter() if _enable_shooter else None
 69        self.feed = subsystem.mechanisms.shooter.Feed() if _enable_feed else None
 70        self.hood = subsystem.mechanisms.shooter.createHood(consts.HoodConstants, HoodConfig) if _enable_hood else None
 71        self.hopper = subsystem.Hopper() if _enable_hopper else None
 72        self.intake_position = subsystem.IntakePosition() if _enable_intake_position else None
 73        self.intake_roller = subsystem.IntakeRoller() if _enable_intake_roller else None
 74        self.robot_state = RobotState()
 75        # Alliance instantiation
 76        self.updateAlliance()
 77
 78        # Initialize timer
 79        self.timer = wpilib.Timer()
 80        self.timer.start()
 81
 82        # HID setup — config-driven via InputFactory
 83        wpilib.DriverStation.silenceJoystickConnectionWarning(True)
 84        self.factory = InputFactory(config_path="data/inputs/2026bot.yaml")
 85
 86        # Speed toggle state
 87        self._drive_scale_slow = 0.25
 88        self._drive_scale_fast = 1
 89        self._drive_is_slow = False
 90
 91        # TODO: Move input retrieval and binding into commands/{subsystem}_controls.py
 92        # files as part of the subsystem registry refactor. Each subsystem's controls
 93        # module should own its own factory.get*() calls and command wiring.
 94        self._configure_controls()
 95
 96        # Autonomous setup
 97        self.auto_command = None
 98        self.auto_chooser = AutoBuilder.buildAutoChooser()
 99        wpilib.SmartDashboard.putData("Select auto routine", self.auto_chooser)
100
101        # Telemetry setup
102        wpilib.SmartDashboard.putNumber("Drivetrain speed", self._drive_scale_fast)
103        self._enable_telemetry = wpilib.SmartDashboard.getBoolean("enableTelemetry", True)
104        if self._enable_telemetry:
105            self.telemetry = Telemetry(
106                driveTrain=self.drivetrain,
107            )
108
109        wpilib.SmartDashboard.putString("Robot Version", self.getDeployInfo("git-hash"))
110        wpilib.SmartDashboard.putString("Git Branch", self.getDeployInfo("git-branch"))
111
112
113
114    def robotPeriodic(self):
115        self._vision_cycle_counter += 1
116        if self._vision_cycle_counter >= OperatorRobotConfig.vision_update_rate_divisor:
117            self._vision_cycle_counter = 0
118            self.localization.update()
119
120        if self._enable_telemetry and self.telemetry:
121            self.telemetry.runDefaultDataCollections()
122
123        self.field.setRobotPose(self.drivetrain.current_pose())
124
125    def disabledInit(self):
126        self.updateAlliance()
127        self.drivetrain.set_motor_stop_modes(to_drive=True, to_break=True, all_motor_override=True, burn_flash=False)
128        self.drivetrain.stop_driving()
129        self.nfc_battery_tracker.onDisabledInit()
130
131        if self.shooter:
132            self.shooter.setRPM(0)
133            self.shooter.resetOffset()
134        if self.feed:
135            self.feed.stop()
136        if self.hopper:
137            self.hopper.stop()
138        if self.intake_roller:
139            self.intake_roller.stop()
140        if self.intake_position:
141            self.intake_position.disable()
142
143    def disabledPeriodic(self):
144        pass
145
146
147    def autonomousInit(self):
148        self.updateAlliance()
149        self.auto_command = self.auto_chooser.getSelected()
150        if self.auto_command:
151            self.auto_command.schedule()
152            if self.auto_command.getName().lower() == "instantcommand":
153                self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
154        else:
155            self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
156
157    def autonomousPeriodic(self):
158        pass
159
160    def teleopInit(self):
161        self.updateAlliance()
162        if self.auto_command:
163            self.auto_command.cancel()
164            if self.auto_command.getName().lower() == "instantcommand":
165                self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
166        else:
167            self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
168
169        # DefaultDrive: raw square input (diagonals get full per-axis output)
170        # DefaultDriveCircular: remaps circular stick input so diagonals
171        #   reach full speed (use when stick hardware caps diagonal ~70%)
172        self.drivetrain.setDefaultCommand(
173            commands.default_swerve_drive.DefaultDrive(  # TODO: switch back to DefaultDriveCircular
174                self.drivetrain,
175                self.translate_x,
176                self.translate_y,
177                self.rotate,
178                lambda: not self.robot_relative_btn()
179            )
180        )
181
182        if self.hood:
183            self.hood.setDefaultCommand(self.hood.autoAngleCommand())
184
185    def teleopPeriodic(self):
186        pass
187
188    def testInit(self):
189        self.updateAlliance()
190        commands2.CommandScheduler.getInstance().cancelAll()
191        # See teleopInit for DefaultDrive vs DefaultDriveCircular notes
192        self.drivetrain.setDefaultCommand(
193            commands.default_swerve_drive.DefaultDrive(  # TODO: switch back to DefaultDriveCircular
194                self.drivetrain,
195                self.translate_x,
196                self.translate_y,
197                self.rotate,
198                lambda: not self.robot_relative_btn()
199            )
200        )
201        commands2.cmd.run(lambda: self.drivetrain.drive(2, 0, 0, False), self.drivetrain).withTimeout(5).schedule()
202
203        if self.hood:
204            self.hood.setDefaultCommand(
205                self.hood.manualTestCommand(self.hood_angle_input))
206
207    def testPeriodic(self):
208        pass
209
210    def _configure_controls(self) -> None:
211        """Retrieve managed inputs from the factory and wire command bindings.
212
213        TODO: Move into commands/{subsystem}_controls.py files as part of the
214        subsystem registry refactor. Each subsystem's controls module would
215        call register_controls(subsystem, container) and own its own
216        factory.get*() calls and command wiring.
217        """
218        # Managed drive inputs
219        self.translate_x = self.factory.getAnalog("drivetrain.translate_x")
220        self.translate_y = self.factory.getAnalog("drivetrain.translate_y")
221        self.rotate = self.factory.getAnalog("drivetrain.rotate")
222        self.robot_relative_btn = self.factory.getRawButton("drivetrain.robot_relative")
223
224        # Cancel-all: emergency stop all commands
225        self.factory.getButton("drivetrain.cancel_all").bind(
226            commands2.cmd.runOnce(
227                lambda: commands2.CommandScheduler.getInstance().cancelAll()
228            )
229        )
230
231        # Speed toggle: switch between slow and fast drive scale
232        self.factory.getButton("drivetrain.speed_toggle").bind(
233            commands2.cmd.runOnce(self._toggle_drive_scale)
234        )
235
236        # Auto-rotate: align drivetrain to target while held
237        self.factory.getButton("drivetrain.auto_align").bind(
238            commands.auto.pid_to_angle.PIDAlignToTarget(
239                self.drivetrain,
240                lambda: determineShooterTargets2026(self.drivetrain.current_pose, self.alliance),
241                self.translate_x,
242                self.translate_y,
243                lambda: not self.robot_relative_btn(),
244                alignment_angle=Rotation2d.fromDegrees(180)
245            )
246        )
247
248        # Mechanism controls — only registered when subsystems are enabled
249        if self.shooter:
250            self.factory.getButton("shooter.increment_RPM").bind(
251                commands2.cmd.runOnce(lambda: self.shooter.modifyOffset(consts.ShooterConstants.offsetDelta), self.shooter)
252            )
253            self.factory.getButton("shooter.decrement_RPM").bind(
254                commands2.cmd.runOnce(lambda: self.shooter.modifyOffset(-consts.ShooterConstants.offsetDelta), self.shooter)
255            )
256            self.factory.getButton("shooter.reset_RPM_offset").bind(
257                commands2.cmd.runOnce(self.shooter.resetOffset, self.shooter)
258            )
259
260        if self.hood:
261            self.hood_angle_input = self.factory.getAnalog("hood.angle")
262
263        if self.hopper:
264            self.factory.getButton("hopper.toggle_hopper").bind(
265                commands.ball_transport.run_hopper_while_active(self.hopper)
266            )
267
268        if self.intake_position:
269            self.factory.getButton("intake.toggle_deploy").bind(
270                commands.intake_commands.toggle_intake_deploy(self.intake_position)
271            )
272
273        if self.intake_roller:
274            self.factory.getButton("ball_transport.hold_roller").bind(
275                commands.ball_transport.run_roller_while_held(self.intake_roller)
276            )
277
278        if self.shooter and self.hood:
279            self.factory.getButton("shooter.spinup_toggle").bind(
280                commands.shooter_commands.toggle_spinup(self.shooter, self.hood)
281            )
282
283        if self.hopper and self.feed:
284            self.factory.getButton("ball_transport.run_hopper_feed").bind(
285                commands.ball_transport.run_hopper_and_feed(self.hopper, self.feed)
286            )
287
288        #Turret stop
289        # Map all drive axes' scale to a shared SmartDashboard entry.
290        # Dashboard changes and Y-button toggles both write to this path;
291        # the factory auto-syncs the value into all three analogs each cycle.
292        _SPEED_NT = "/SmartDashboard/Drivetrain speed"
293        for analog in (self.translate_x, self.translate_y, self.rotate):
294            analog.mapParamToNtPath(_SPEED_NT, "scale")
295
296    def _toggle_drive_scale(self) -> None:
297        """Toggle between slow and fast drive scale presets.
298
299        Writes the new scale to SmartDashboard; the factory auto-syncs
300        it into all three drive analogs via mapParamToNtPath each cycle.
301        """
302        self._drive_is_slow = not self._drive_is_slow
303        scale = self._drive_scale_slow if self._drive_is_slow else self._drive_scale_fast
304        wpilib.SmartDashboard.putNumber("Drivetrain speed", scale)
305
306    def getDeployInfo(self, key: str) -> str:
307        """Gets the Git SHA of the deployed robot by parsing ~/deploy.json and returning the git-hash from the JSON key OR if deploy.json is unavailable will return "unknown"
308            example deploy.json: '{"deploy-host": "DESKTOP-80HA89O", "deploy-user": "ehsra", "deploy-date": "2023-03-02T17:54:14", "code-path": "blah", "git-hash": "3f4e89f138d9d78093bd4869e0cac9b61becd2b9", "git-desc": "3f4e89f-dirty", "git-branch": "fix-recal-nbeasley"}
309
310        Args:
311            key (str): The desired json key to get. Popular onces are git-hash, deploy-host, deploy-user
312
313        Returns:
314            str: Returns the value of the desired deploy key
315        """
316        json_object = None
317        home = str(Path.home()) + os.path.sep
318        release_file = home + 'py' + os.path.sep + "deploy.json"
319        try:
320            # Read from ~/deploy.json
321            with open(release_file, "r") as openfile:
322                json_object = json.load(openfile)
323                if key in json_object:
324                    return json_object[key]
325                else:
326                    return f"Key: {key} Not Found in JSON"
327        except OSError:
328            return "unknown"
329        except json.JSONDecodeError:
330            return "bad json in deploy file check for unescaped "
331
332    def updateAlliance(self) -> None:
333        """
334        Update the alliance the robot is on
335        """
336        self.alliance = wpilib.DriverStation.getAlliance()
337        self.drivetrain.update_alliance_flag(self.alliance)
RobotSwerve(is_disabled: Callable[[], bool])
 37    def __init__(self, is_disabled: Callable[[], bool]) -> None:
 38        # networktables setup
 39        self.field = wpilib.Field2d()
 40        wpilib.SmartDashboard.putData("Field", self.field)
 41
 42        # In simulation, pre-seed CANcoder supply voltage so the absolute
 43        # encoders report valid data when swerve modules call
 44        # baseline_relative_encoders() during construction.
 45        if wpilib.RobotBase.isSimulation():
 46            import phoenix6
 47            for base_id in OperatorRobotConfig.swerve_module_channels:
 48                encoder_id = base_id + 2
 49                encoder = phoenix6.hardware.CANcoder(encoder_id)
 50                encoder.sim_state.set_supply_voltage(12.0)
 51
 52        # Subsystem instantiation
 53        self.drivetrain = subsystem.drivetrain.swerve_drivetrain.SwerveDrivetrain()
 54        self.health_and_status = HealthAndStatus()
 55        self.nfc_battery_tracker = NfcBatteryTracker()
 56        from subsystem.localization.localization import Localization
 57        self.localization = Localization(self.drivetrain, field=self.field)
 58        self._vision_cycle_counter = 0
 59
 60        # Mechanism subsystems — toggle each to True/False individually
 61        _enable_shooter = False
 62        _enable_feed = False
 63        _enable_hood = False
 64        _enable_hopper = False
 65        _enable_intake_position = False
 66        _enable_intake_roller = True
 67
 68        self.shooter = subsystem.mechanisms.shooter.Shooter() if _enable_shooter else None
 69        self.feed = subsystem.mechanisms.shooter.Feed() if _enable_feed else None
 70        self.hood = subsystem.mechanisms.shooter.createHood(consts.HoodConstants, HoodConfig) if _enable_hood else None
 71        self.hopper = subsystem.Hopper() if _enable_hopper else None
 72        self.intake_position = subsystem.IntakePosition() if _enable_intake_position else None
 73        self.intake_roller = subsystem.IntakeRoller() if _enable_intake_roller else None
 74        self.robot_state = RobotState()
 75        # Alliance instantiation
 76        self.updateAlliance()
 77
 78        # Initialize timer
 79        self.timer = wpilib.Timer()
 80        self.timer.start()
 81
 82        # HID setup — config-driven via InputFactory
 83        wpilib.DriverStation.silenceJoystickConnectionWarning(True)
 84        self.factory = InputFactory(config_path="data/inputs/2026bot.yaml")
 85
 86        # Speed toggle state
 87        self._drive_scale_slow = 0.25
 88        self._drive_scale_fast = 1
 89        self._drive_is_slow = False
 90
 91        # TODO: Move input retrieval and binding into commands/{subsystem}_controls.py
 92        # files as part of the subsystem registry refactor. Each subsystem's controls
 93        # module should own its own factory.get*() calls and command wiring.
 94        self._configure_controls()
 95
 96        # Autonomous setup
 97        self.auto_command = None
 98        self.auto_chooser = AutoBuilder.buildAutoChooser()
 99        wpilib.SmartDashboard.putData("Select auto routine", self.auto_chooser)
100
101        # Telemetry setup
102        wpilib.SmartDashboard.putNumber("Drivetrain speed", self._drive_scale_fast)
103        self._enable_telemetry = wpilib.SmartDashboard.getBoolean("enableTelemetry", True)
104        if self._enable_telemetry:
105            self.telemetry = Telemetry(
106                driveTrain=self.drivetrain,
107            )
108
109        wpilib.SmartDashboard.putString("Robot Version", self.getDeployInfo("git-hash"))
110        wpilib.SmartDashboard.putString("Git Branch", self.getDeployInfo("git-branch"))
def
robotPeriodic(self):
114    def robotPeriodic(self):
115        self._vision_cycle_counter += 1
116        if self._vision_cycle_counter >= OperatorRobotConfig.vision_update_rate_divisor:
117            self._vision_cycle_counter = 0
118            self.localization.update()
119
120        if self._enable_telemetry and self.telemetry:
121            self.telemetry.runDefaultDataCollections()
122
123        self.field.setRobotPose(self.drivetrain.current_pose())
def
disabledInit(self):
125    def disabledInit(self):
126        self.updateAlliance()
127        self.drivetrain.set_motor_stop_modes(to_drive=True, to_break=True, all_motor_override=True, burn_flash=False)
128        self.drivetrain.stop_driving()
129        self.nfc_battery_tracker.onDisabledInit()
130
131        if self.shooter:
132            self.shooter.setRPM(0)
133            self.shooter.resetOffset()
134        if self.feed:
135            self.feed.stop()
136        if self.hopper:
137            self.hopper.stop()
138        if self.intake_roller:
139            self.intake_roller.stop()
140        if self.intake_position:
141            self.intake_position.disable()
def
autonomousInit(self):
147    def autonomousInit(self):
148        self.updateAlliance()
149        self.auto_command = self.auto_chooser.getSelected()
150        if self.auto_command:
151            self.auto_command.schedule()
152            if self.auto_command.getName().lower() == "instantcommand":
153                self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
154        else:
155            self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
def
teleopInit(self):
160    def teleopInit(self):
161        self.updateAlliance()
162        if self.auto_command:
163            self.auto_command.cancel()
164            if self.auto_command.getName().lower() == "instantcommand":
165                self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
166        else:
167            self.drivetrain.reset_pose_estimator(self.drivetrain.get_default_starting_pose())
168
169        # DefaultDrive: raw square input (diagonals get full per-axis output)
170        # DefaultDriveCircular: remaps circular stick input so diagonals
171        #   reach full speed (use when stick hardware caps diagonal ~70%)
172        self.drivetrain.setDefaultCommand(
173            commands.default_swerve_drive.DefaultDrive(  # TODO: switch back to DefaultDriveCircular
174                self.drivetrain,
175                self.translate_x,
176                self.translate_y,
177                self.rotate,
178                lambda: not self.robot_relative_btn()
179            )
180        )
181
182        if self.hood:
183            self.hood.setDefaultCommand(self.hood.autoAngleCommand())
def
testInit(self):
188    def testInit(self):
189        self.updateAlliance()
190        commands2.CommandScheduler.getInstance().cancelAll()
191        # See teleopInit for DefaultDrive vs DefaultDriveCircular notes
192        self.drivetrain.setDefaultCommand(
193            commands.default_swerve_drive.DefaultDrive(  # TODO: switch back to DefaultDriveCircular
194                self.drivetrain,
195                self.translate_x,
196                self.translate_y,
197                self.rotate,
198                lambda: not self.robot_relative_btn()
199            )
200        )
201        commands2.cmd.run(lambda: self.drivetrain.drive(2, 0, 0, False), self.drivetrain).withTimeout(5).schedule()
202
203        if self.hood:
204            self.hood.setDefaultCommand(
205                self.hood.manualTestCommand(self.hood_angle_input))
def
getDeployInfo(self, key: str) -> str:
306    def getDeployInfo(self, key: str) -> str:
307        """Gets the Git SHA of the deployed robot by parsing ~/deploy.json and returning the git-hash from the JSON key OR if deploy.json is unavailable will return "unknown"
308            example deploy.json: '{"deploy-host": "DESKTOP-80HA89O", "deploy-user": "ehsra", "deploy-date": "2023-03-02T17:54:14", "code-path": "blah", "git-hash": "3f4e89f138d9d78093bd4869e0cac9b61becd2b9", "git-desc": "3f4e89f-dirty", "git-branch": "fix-recal-nbeasley"}
309
310        Args:
311            key (str): The desired json key to get. Popular onces are git-hash, deploy-host, deploy-user
312
313        Returns:
314            str: Returns the value of the desired deploy key
315        """
316        json_object = None
317        home = str(Path.home()) + os.path.sep
318        release_file = home + 'py' + os.path.sep + "deploy.json"
319        try:
320            # Read from ~/deploy.json
321            with open(release_file, "r") as openfile:
322                json_object = json.load(openfile)
323                if key in json_object:
324                    return json_object[key]
325                else:
326                    return f"Key: {key} Not Found in JSON"
327        except OSError:
328            return "unknown"
329        except json.JSONDecodeError:
330            return "bad json in deploy file check for unescaped "
Gets the Git SHA of the deployed robot by parsing ~/deploy.json and returning the git-hash from the JSON key OR if deploy.json is unavailable will return "unknown" example deploy.json: '{"deploy-host": "DESKTOP-80HA89O", "deploy-user": "ehsra", "deploy-date": "2023-03-02T17:54:14", "code-path": "blah", "git-hash": "3f4e89f138d9d78093bd4869e0cac9b61becd2b9", "git-desc": "3f4e89f-dirty", "git-branch": "fix-recal-nbeasley"}
Args: key (str): The desired json key to get. Popular onces are git-hash, deploy-host, deploy-user
Returns: str: Returns the value of the desired deploy key